- Combining sensory, motor and swarm intelligence for manufacturing, medical and defense AI platforms
- President Bae Choong-sik to don 'Iron Man'-style wearable robot, unveil future strategy Tuesday
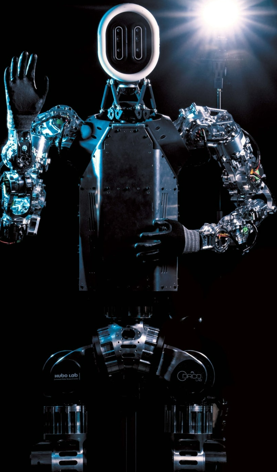
"The outcome of physical AI depends not on how closely a robot resembles a human, but on how broadly AI that understands and moves through the real world can be deployed across different industries." — KAIST President Bae Choong-sik
KAIST is moving away from its previous focus on robot form and performance, placing a major bet on next-generation physical AI technology that can sense, move and collaborate in the real world.
The university announced it will hold "Physical AI Korea 2026" on Tuesday, where it will present its vision and core strategy for building a physical AI industry ecosystem in South Korea.
At the event, KAIST President Bae will define physical AI not as mere humanoid robot development but as a next-generation AI technology combining sensory intelligence, motor intelligence and swarm intelligence, and will unveil the university's research, education and startup strategies for spreading the technology across industries.
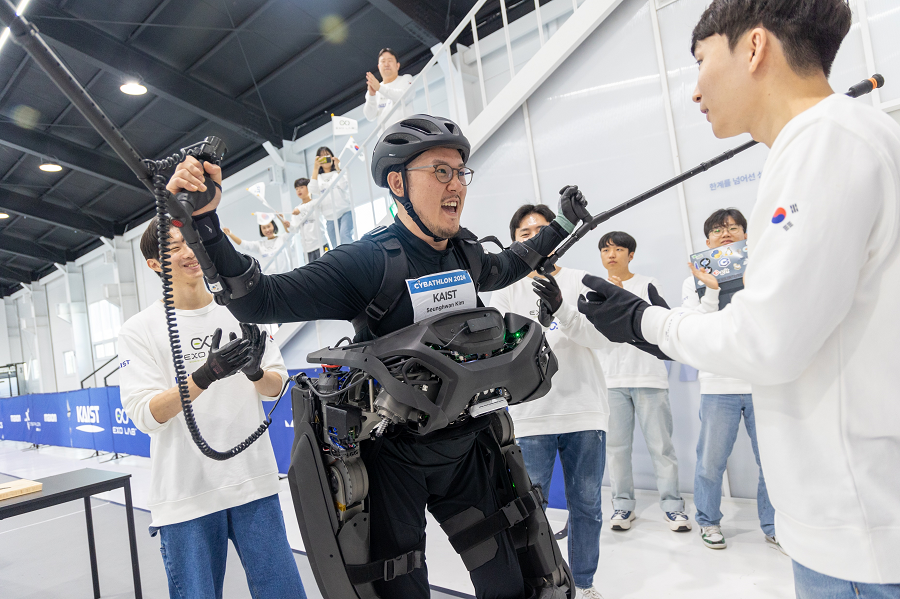
Bae will also take the stage wearing a wearable robot reminiscent of the suit from "Iron Man."
The device, developed by the research team of KAIST Professor Kong Kyoung-chul, is designed to assist the wearer's gait while using movement data to analyze health information — a demonstration of physical AI technology in action.
While existing wearable robots have focused on helping people with disabilities walk and undergo rehabilitation, the technology can evolve into an intelligence platform capable of analyzing a person's movement patterns and overall health, KAIST said.
KAIST's physical AI strategy rests on three pillars.
The first, sensory intelligence, analyzes physical signals such as force, motion and position to help robots understand their surroundings and the condition of nearby people. Motor intelligence builds on that to generate context-appropriate movements — walking, grasping objects and the like. Swarm intelligence enables multiple robots and systems to share information and make decisions and take actions collectively.
KAIST plans to develop these core technologies not as tools exclusive to humanoid robots, but as a common platform applicable across industrial robots, wearable robots and autonomous driving systems.
To that end, the university intends to organically connect precision actuators, physical data measurement and processing technology, large-scale data centers and autonomous control systems.
The event will also showcase a range of world-class robotics technologies KAIST has built up over the years.
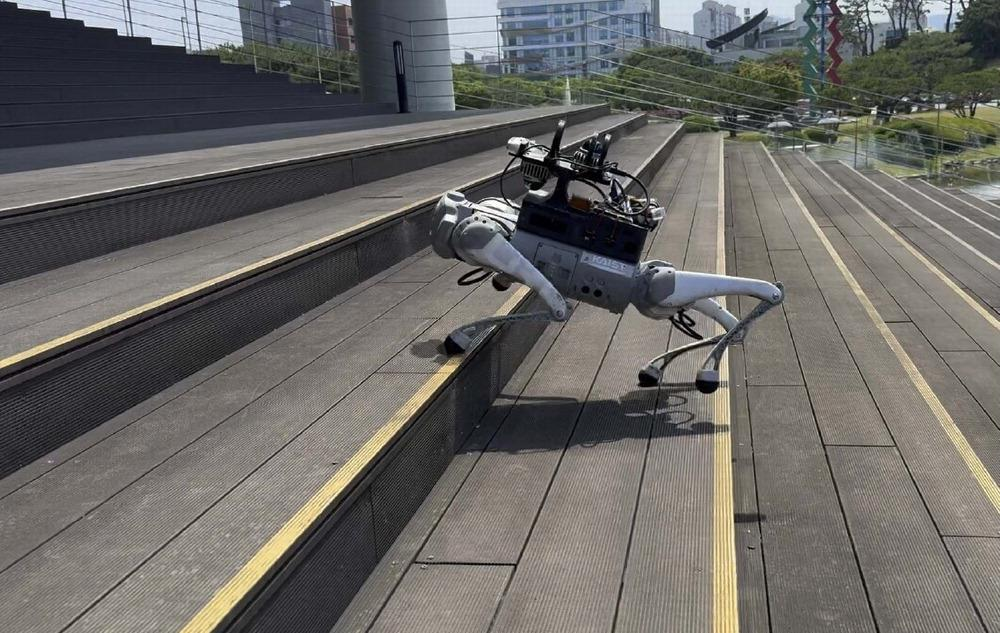
The research team of mechanical engineering Professor Park Hae-won will present a humanoid robot capable of carrying objects weighing more than 15 kilograms. Drawing on experience developing the quadruped robot HOUND, the team is working on technology that enables stable movement across complex terrain, including walking, running and jumping.
The research team of electrical engineering Professor Shim Hyun-chul will demonstrate PIBOT, a humanoid pilot robot. PIBOT is being developed to directly operate cockpit controls, analyze flight data and carry out piloting missions.
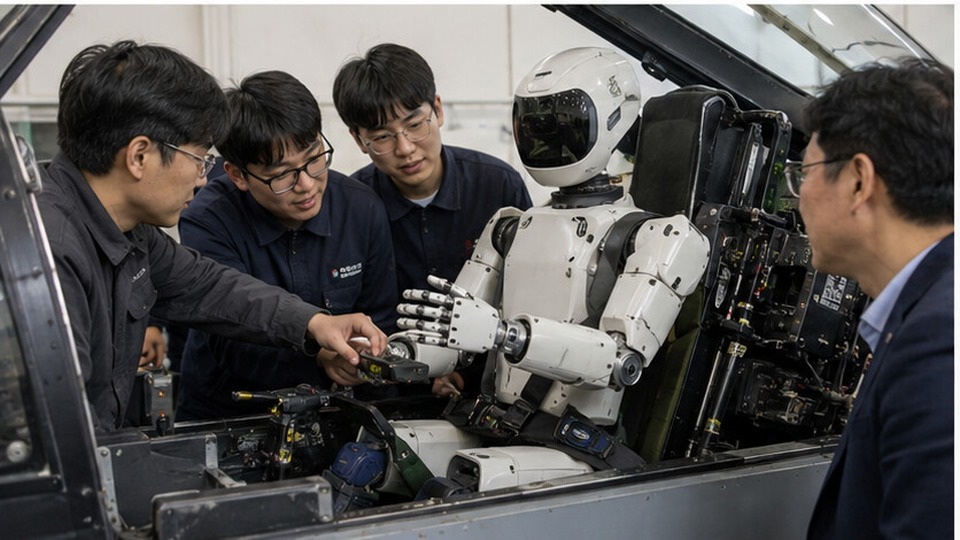
The research team of Professor Myung Hyun will introduce autonomous navigation technology that uses cameras and lidar to determine position and plan movement routes in unfamiliar spaces without human guidance.
The research team of Professor Bae Hyun-min will present precision robot actuation technology combining motors, sensors and control systems, while the team of Professor Kong Kyoung-chul will demonstrate wearable robot technology that reads a user's intended movements to assist walking.
KAIST also plans to accelerate the transfer of foundational technologies developed in its laboratories into real-world industries.
The university will expand the commercialization and industrial application of its robotics technology through faculty-founded companies including Angel Robotics and Lion Robotics. The strategy calls for strengthening a collaborative structure in which the university develops core platform technologies while the startups handle product development and market entry.
"We will connect KAIST's accumulated expertise in robotics, AI, sensors and actuation into a unified physical AI foundation that can be deployed in real industrial settings," Bae is expected to say. "We will build an ecosystem where research outcomes lead to talent development, entrepreneurship and industrial innovation."
nbgkoo@heraldcorp.com