Team accurately estimates camera position despite organ deformation and light reflection, raising hopes for automated robotic surgery
South Korean researchers have developed an AI-powered technology that precisely tracks the position of an endoscopic camera during surgery, taking first place at a prestigious global medical imaging AI competition.
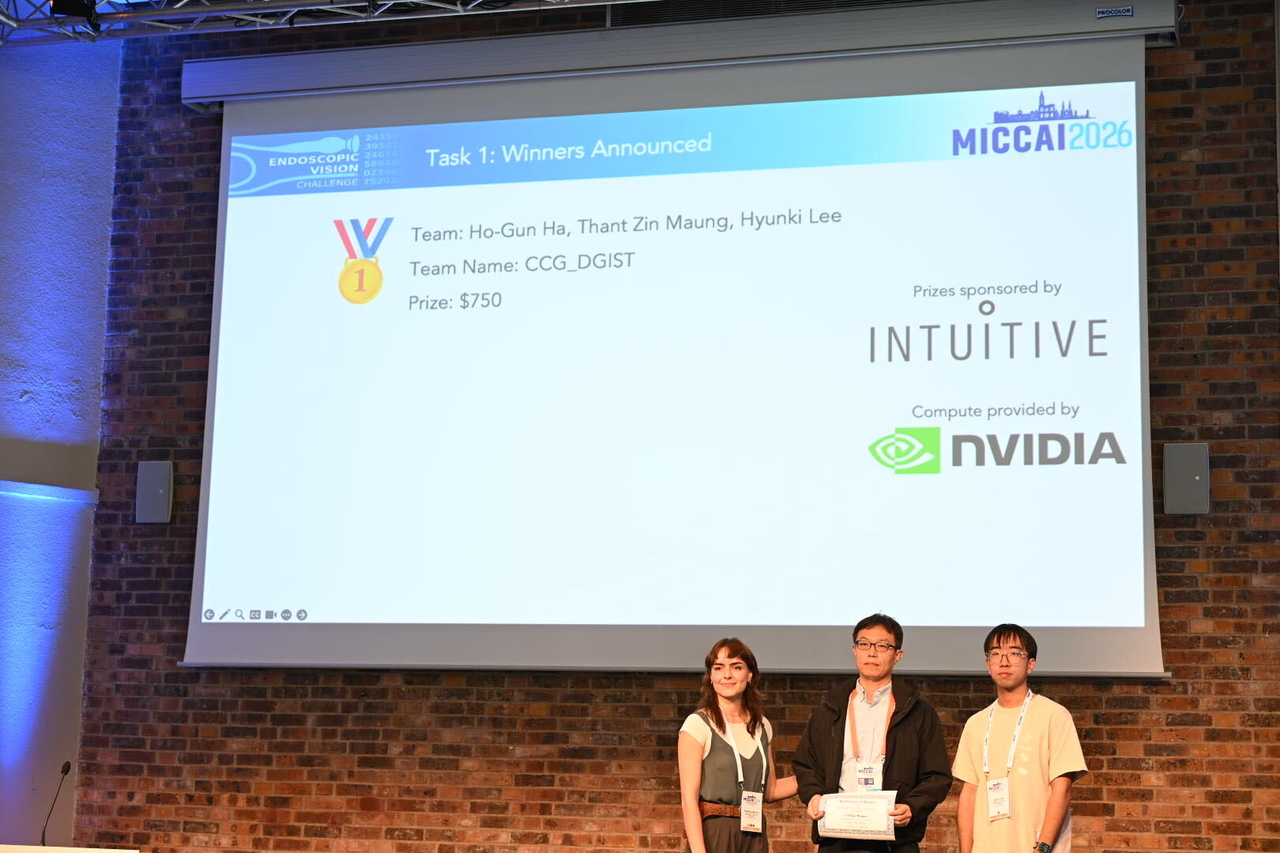
The Daegu Gyeongbuk Institute of Science and Technology said Wednesday that a research team led by Principal Researcher Lee Hyun-ki of the institute's Intelligent Robotics Research Division claimed first place in the 3D camera pose estimation category of the EndoVis Challenge, held as part of the 2026 Medical Image Computing and Computer Assisted Intervention conference, known as MICCAI 2026.
The team placed second in 2024 and first in 2025, making this year's win their third consecutive podium finish and cementing their standing in the medical imaging AI field.
The competition, co-sponsored by global medical robotics company Intuitive and Nvidia, evaluates core technologies needed for robot-assisted minimally invasive surgery. The central benchmark is how accurately a system can estimate the relative positions of two independent endoscopic cameras by analyzing the footage each captures.
In endoscopic surgery, knowing the precise position of the camera is essential for reconstructing the surgical site in three dimensions and controlling robotic movements with accuracy.
In real operating environments, however, organ shapes shift constantly with the patient's breathing and the movement of surgical instruments. Strong lighting causes glare, while smoke and bleeding further degrade the accuracy of image analysis.
To overcome these challenges, the team combined an existing deep learning model for visual pose estimation with a "Dense Matcher" technique that precisely links subtle feature points within images.
The approach reduced the analytical errors that conventional vision transformer-based AI models produce when confronted with organ surface deformation or light reflection, enabling accurate 3D camera positioning even in complex surgical environments.
The technology is expected to find use not only in real-time navigation systems that feed surgeons precise positional data during operations, but also in autonomous surgical systems that allow robots to perceive their surroundings and control their own movements.
"We will accelerate practical research so that this technology can be applied in actual robotic surgery settings and patient treatment, through close clinical collaboration with regional hub hospitals," Lee said. "We will continue our research so that DGIST can emerge as a global center for medical image processing and AI research."
nbgkoo@heraldcorp.com